Three Modes, Infinite Possibilities
Switch seamlessly between manual control, autonomous navigation, and precision tracking
Manual Mode
Full remote control via Bluetooth or RF module. Navigate with precision using directional commands for testing and entertainment.
- Real-time wireless control
- Variable speed control
- Instant response time
- Multi-direction movement
Obstacle Avoiding
Autonomous navigation using ultrasonic sensors. The car detects obstacles and intelligently plots alternative paths in real-time.
- Ultrasonic distance detection
- Smart path planning
- 360° awareness
- Collision prevention
Line Following
Precise path tracking using IR sensors. Perfect for automated delivery routes and predefined navigation patterns.
- IR sensor array
- PID control algorithm
- High-speed tracking
- Sharp turn handling
Technical Specifications
Powered by Arduino and precision-engineered components
Microcontroller
Model:Arduino Nano
Specs:ATmega328P, 16MHz, 32KB Flash
Motors & Driver
Type:6V DC Motors (×2)
Driver:L293D Motor Driver
Voltage:6V
Sensors & Modules
Ultrasonic Sensor
HC-SR04
Distance measurement
IR Sensors (×2)
FC-51
Line detection
Bluetooth Module
HC-06
Wireless control
Servo Motor
SG-90
Ultrasonic sensor rotation
Power System
Battery:2× 3.7V Li-ion (7.4V)
Runtime:45-60 minutes
Physical Specs
Dimensions:25cm × 18cm
Weight:450g
Project Gallery
Behind the scenes of building the TriModeCar
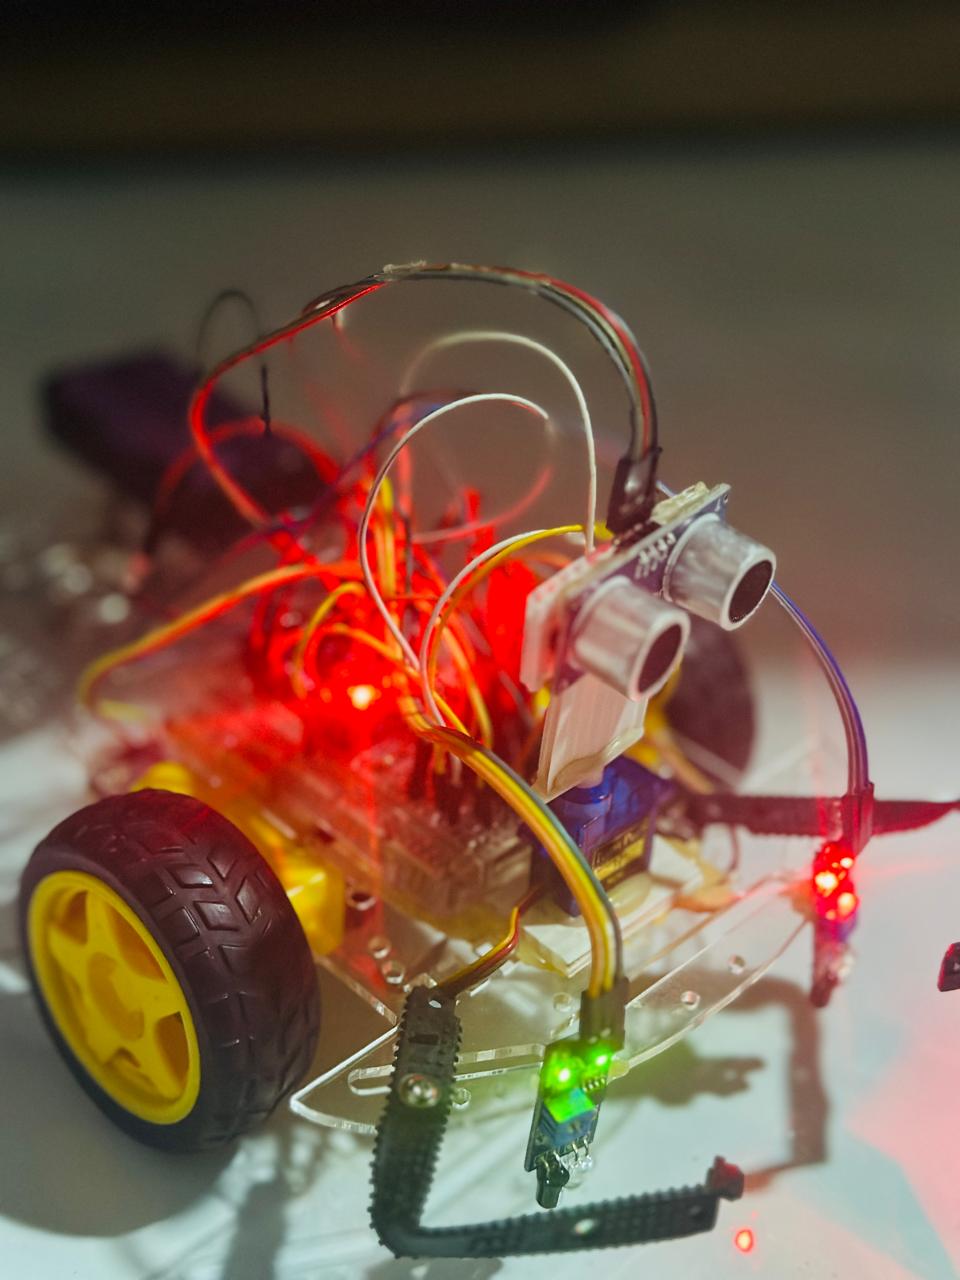
Front View
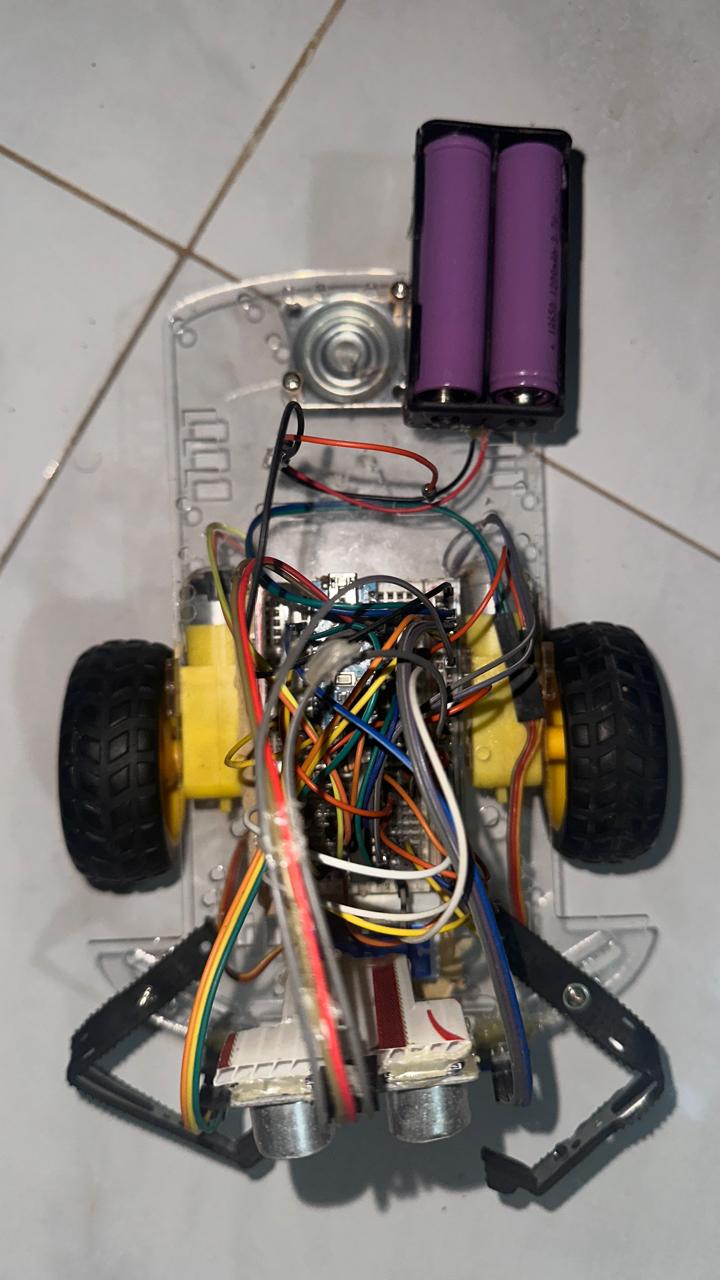
Top View
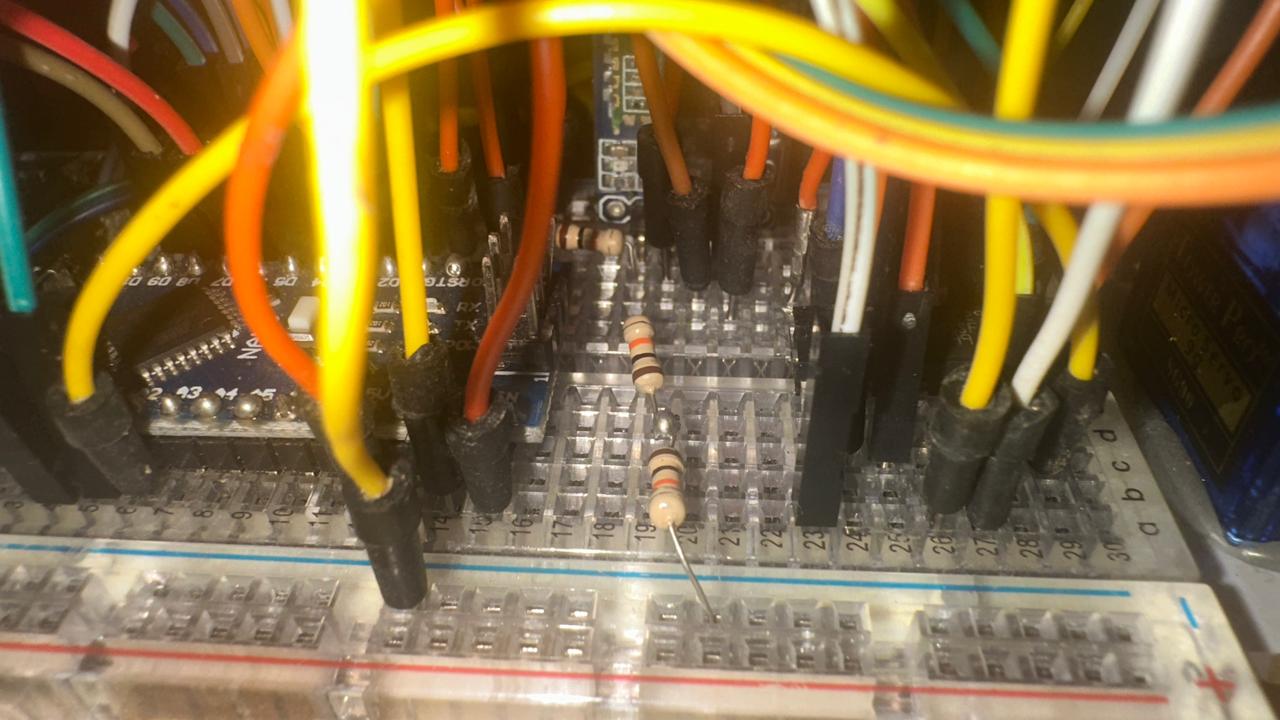
Voltage Divider
To reduce voltage to protect the Bluetooth Module
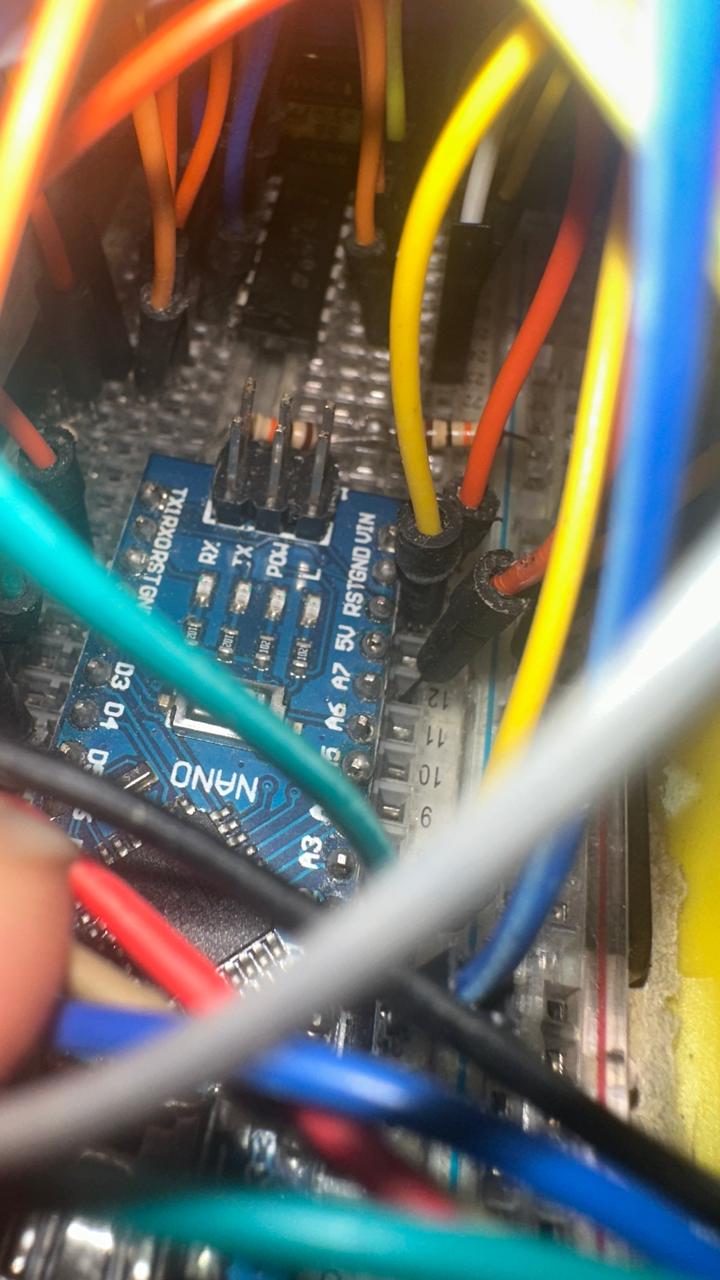
L293D Motor Driver IC